Research
Misc.
My research focuses on robot learning for dexterous manipulation. I aim to enhance robotic capabilities under resource constraints by effectively leveraging diverse data sources and available physical resources.
A key emphasis of my work is extending task horizons, enabling robots to perform long-horizon, multi-stage tasks and multitasking, as well as more delicate behaviors such as nonprehensile manipulation. Ultimately, my goal is to advance robotic manipulation toward human-level dexterity, enabling robots to learn, adapt, and interact with the physical world more effectively.
(* indicates equal contribution, † indicates equal advising)
Preprint
Your browser does not support the video tag.
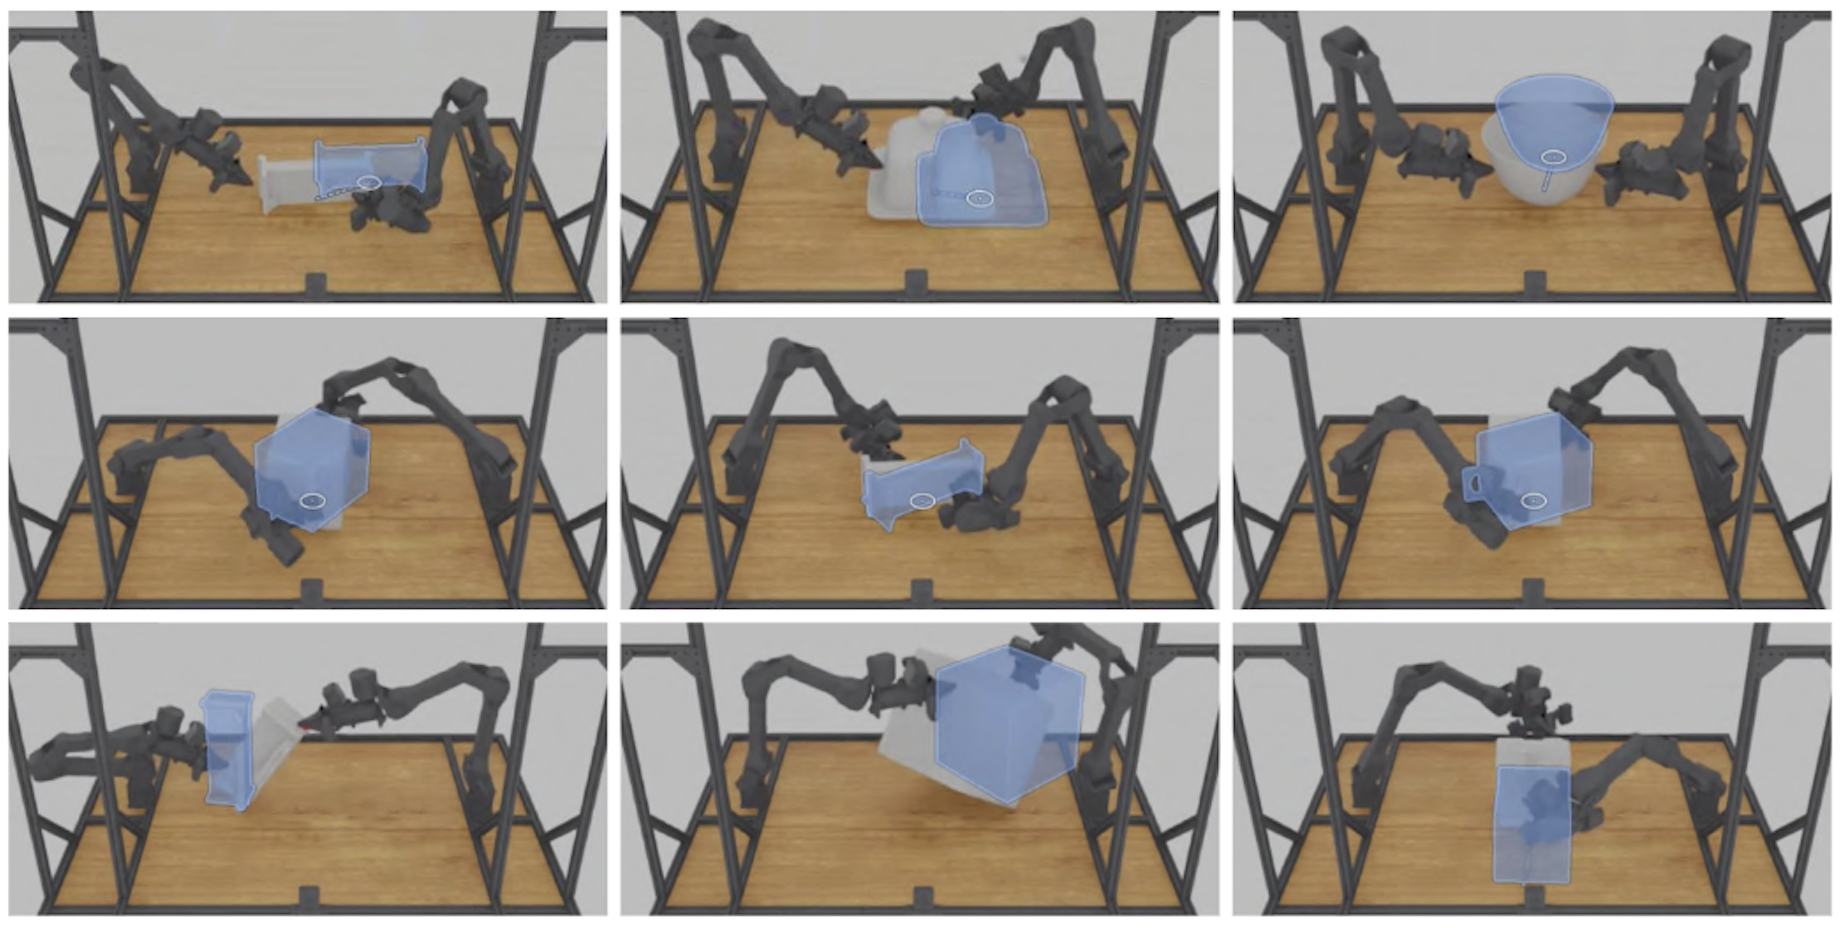
BiREPO: Learning Goal-Conditioned Bimanual Nonprehensile Pose Reconfiguration Primitives on Diverse Objects
Yunshuang Li Xinyi Yu *,
Jason Chen *,
Changyang Zhang ,
Faiz Aladin ,
Gaurav Sukhatme ,
Daniel Seita
Under review, 2026
arXiv
/
project page
/
code
Preprint
Your browser does not support the video tag.
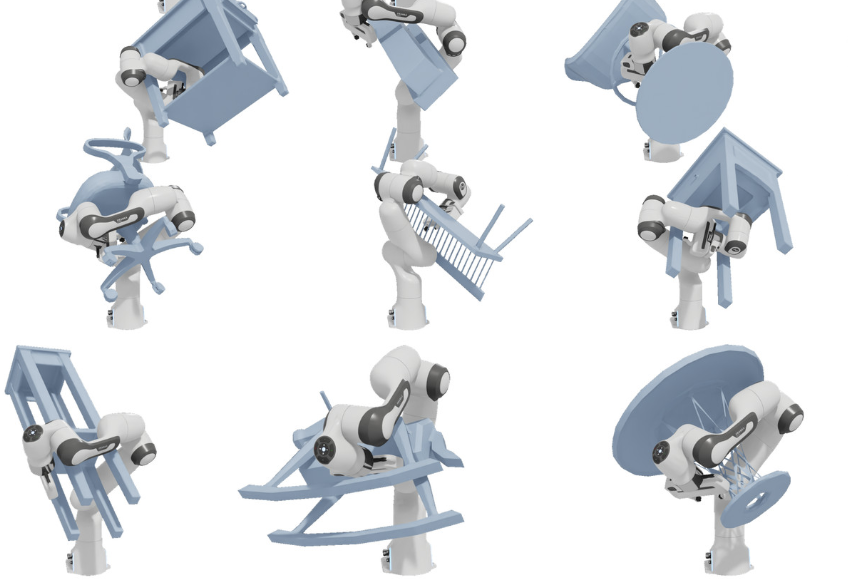
ARMFUL: Learning Whole-Arm Grasp Configurations for Single-Arm Pickup of Large Objects
Xinyi Yu ,
Yunshuang Li Daniel Seita ,
Gaurav Sukhatme
Under review, 2026
arXiv
/
project page
/
code
IROS
Your browser does not support the video tag.
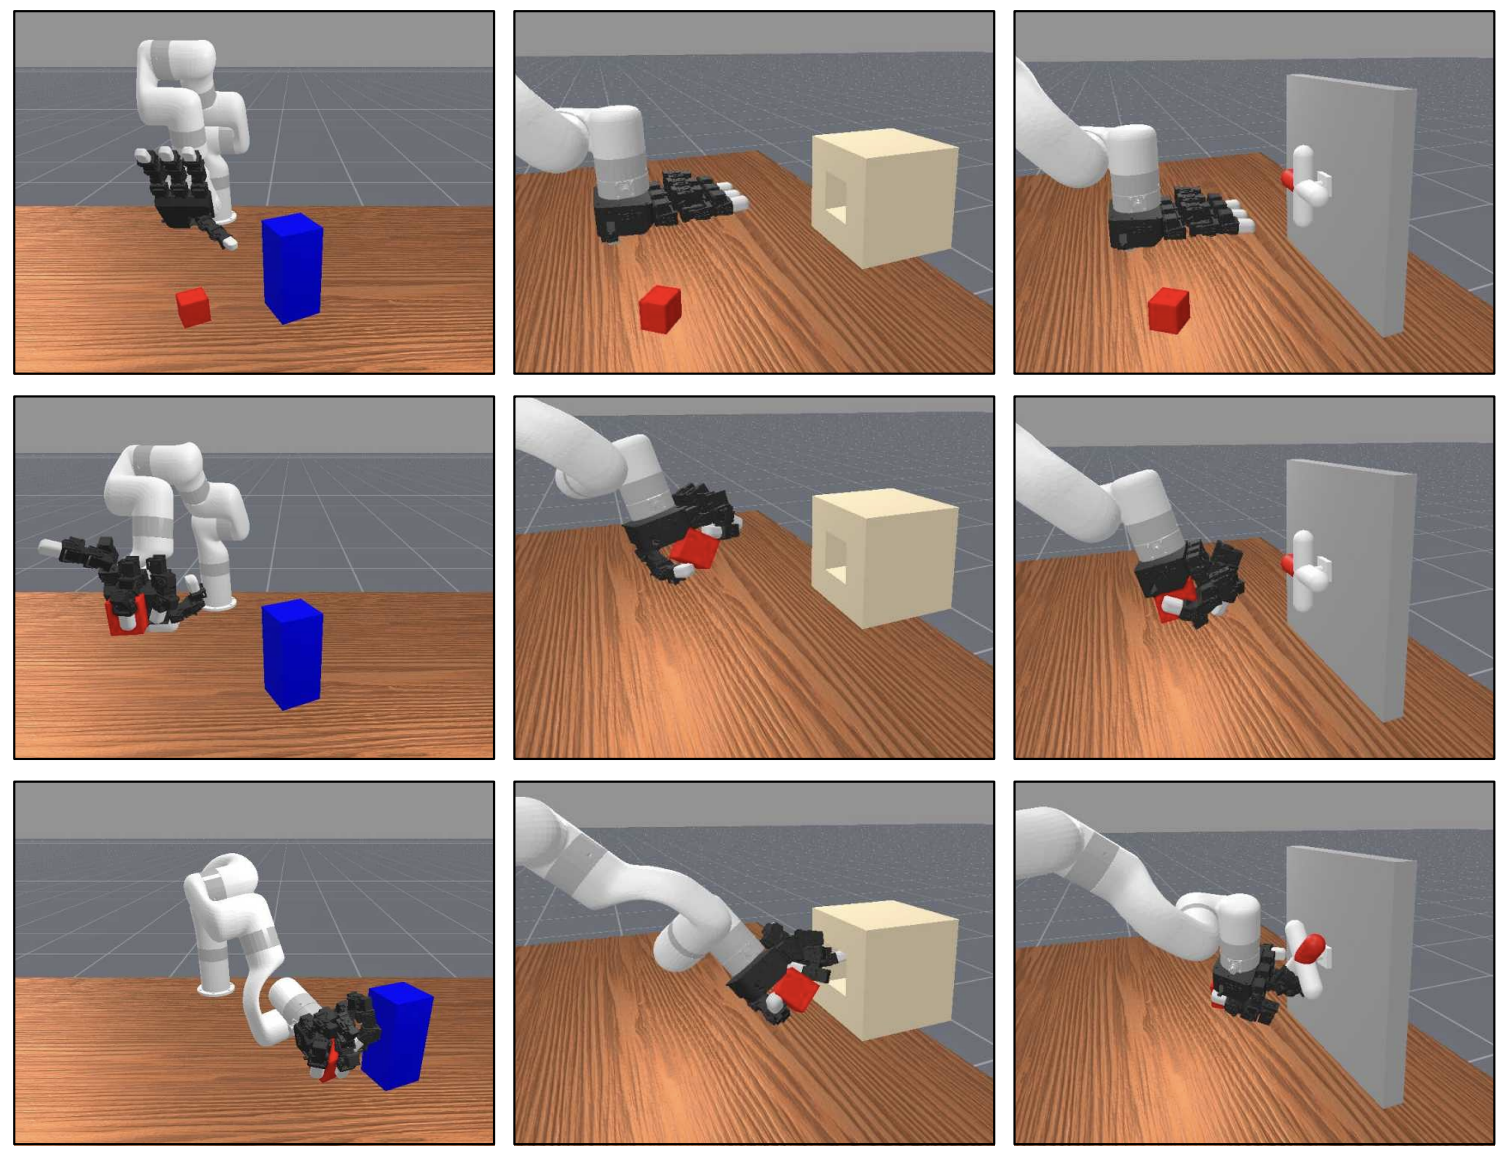
HANDFUL: Sequential Grasp-Conditioned Dexterous Manipulation with Resource Awareness
Ethan Foong *,
Yunshuang Li Hao Jiang ,
Gaurav Sukhatme ,
Daniel Seita
IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) 2026
arXiv
/
project page
/
video
/
code
ICRA
Your browser does not support the video tag.
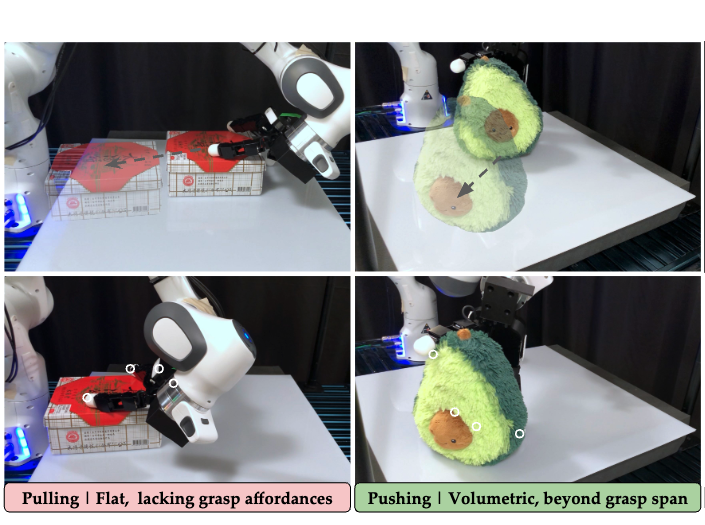
Learning Geometry-Aware Nonprehensile Pushing and Pulling
with Dexterous Hands
Yunshuang Li Yiyang Ling ,
Gaurav Sukhatme † ,
Daniel Seita †
International Conference on Robotics and Automation (ICRA) 2026
arXiv
/
project page
/
video
/
code
CoRL
Your browser does not support the video tag.
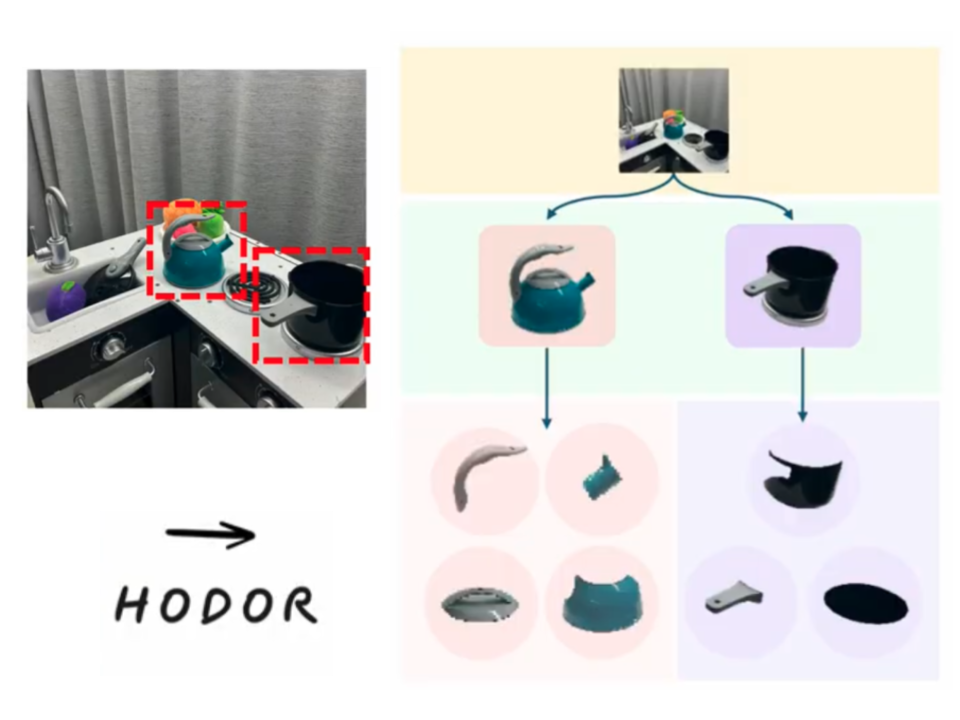
Task-Oriented Hierarchical Object Decomposition for Visuomotor Control
Yunshuang Li Bernadette Bucher ,
Dinesh Jayaraman
Conference on Robot Learning (CoRL), 2024
arXiv
/
project page
/
video
/
code
RSS
Your browser does not support the video tag.
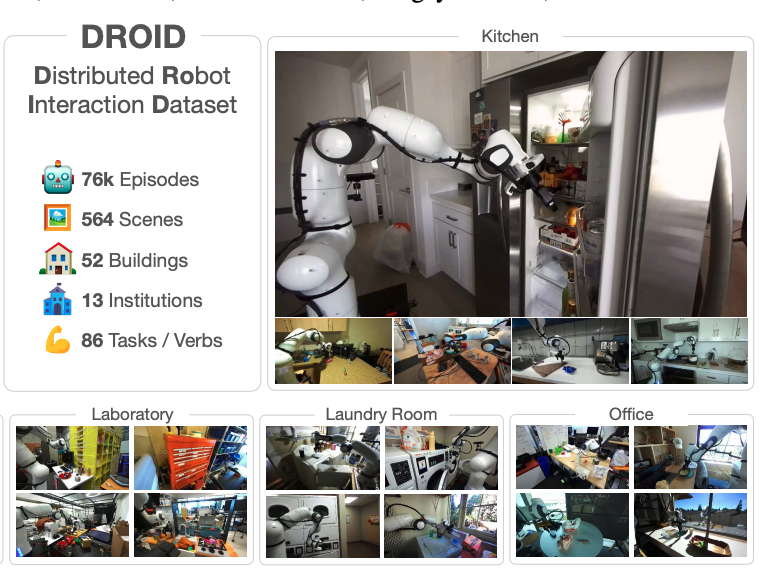
DROID: A Large-Scale In-The-Wild Robot Manipulation Dataset
Robotics: Science and Systems (RSS), 2024
arXiv
/
project page
/
video
ICRA
Your browser does not support the video tag.
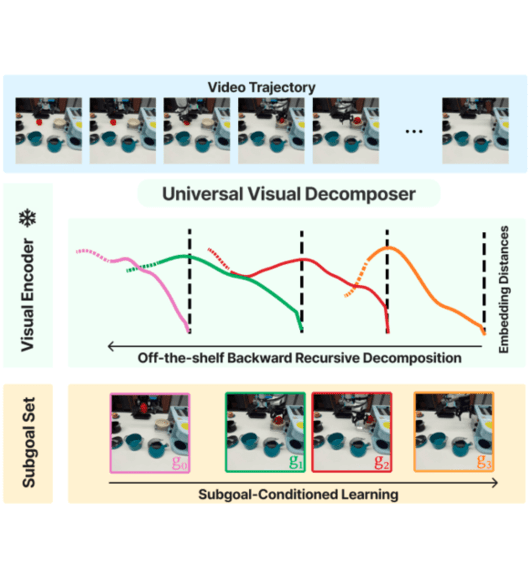
Universal Visual Decomposer: Long-Horizon Manipulation Made Easy
Zichen Zhang *,
Yunshuang Li Osbert Bastani ,
Abhishek Gupta ,
Dinesh Jayaraman ,
Yecheng Jason Ma † ,
Luca Weihs †
LEAP worshop @ CoRL 2023 (Oral, Best paper award) FMDM worshop @ NeurIPS 2023 (Oral, 6/112) International Conference on Robotics and Automation (ICRA) 2024 (Best Computer Vision Paper Finalist)
arXiv
/
project page
/
video
/
code
ICRA
Your browser does not support the video tag.
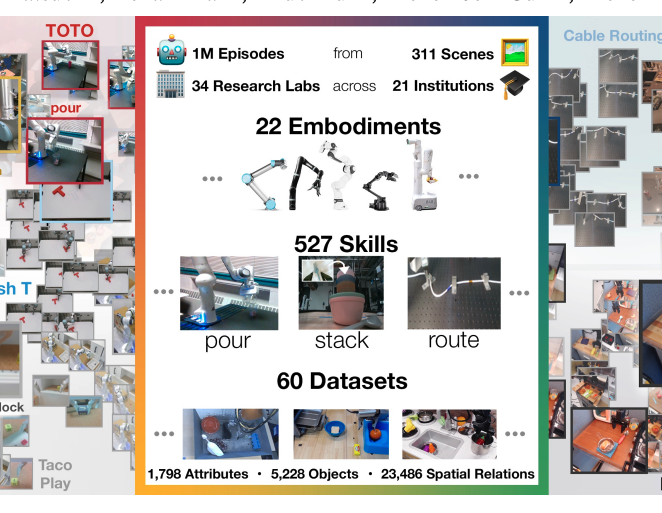
Open X-Embodiment: Robotic Learning Datasets and RT-X Models
International Conference on Robotics and Automation (ICRA) 2024 (Best Conference Paper Award)
arXiv
/
project page
/
video
/
code
CoRL
Your browser does not support the video tag.
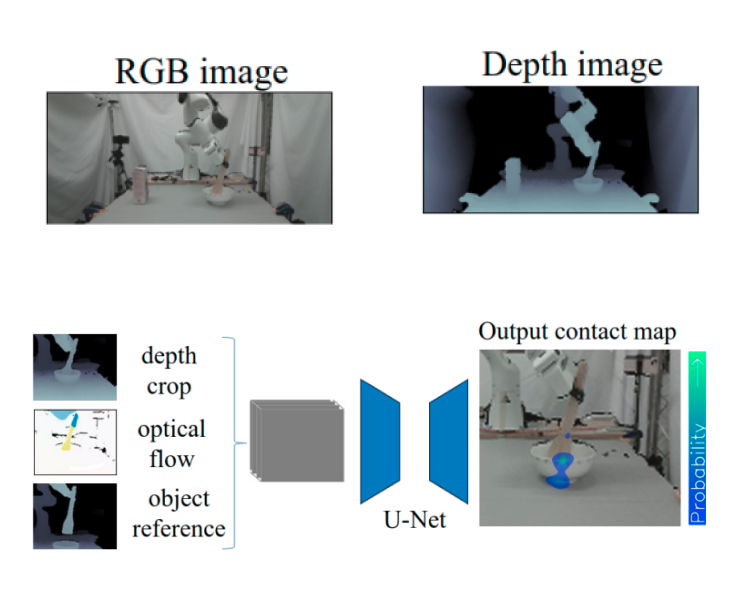
Vision-Based Contact Localization Without Touch or Force Sensing
Yunshuang Li Michael Posa ,
Dinesh Jayaraman
Conference on Robot Learning (CoRL), 2023
arXiv
/
project page
/
video
/
code
Misc.
Things I'm dexterous at that have nothing to do with robots: dancing, pilates, pickleball and (as of recently) baking.
Things I'm not: resisting LA's weather as an excuse to be outside.
Four cities, zero-shot each time.